DONIC bimanual tracker hits 86.79% success on unseen trajectories
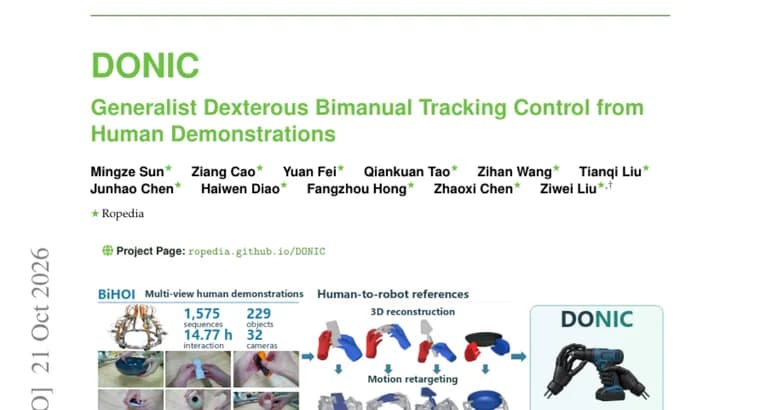
A paper listed on Hugging Face Papers introduces DONIC, which the authors call the first generalist bimanual tracker jointly trained across operation categories and human-motion sources. The problem they describe: existing dexterous reference-tracking models focus mainly on single-hand manipulation and a limited range of interactions, which leaves the two-handed dexterous behaviors common in real life unaddressed. Two things make a generalist bimanual tracker hard, according to the authors: contact-rich bimanual manipulation data is scarce, and coordinating contacts between two hands is more complex.
The paper answers with two contributions. The first is DONIC itself. The second is BiHOI, a multi-view dataset of 1,575 sequences spanning 229 objects. It emphasizes sustained bimanual interaction, and the reconstructed interactions are retargeted into robot references.
Three design choices are described. DONIC combines proximal policy optimization with behavioral cloning in a feedback loop that recycles verified successful executions into training demonstrations. An object-centered per-hand reward keeps object-motion feedback while supervising each hand according to its reference contact role. And Clip-Centered Advantages remove reference-dependent advantage offsets while preserving within-trajectory differences. Together, the authors say, these designs let one single policy learn coordinated manipulation across heterogeneous references.
On results, the paper reports that without finetuning a single checkpoint achieves 86.79% success on unseen trajectories of training objects and 57.32% on held-out objects. It says this surpasses the state-of-the-art bimanual tracking baselines by 77.36 and 45.73 percentage points. Those are margins over the baselines, not the baselines' own scores.
Key facts
- DONIC is presented as the first generalist bimanual tracker jointly trained across operation categories and human-motion sources.
- BiHOI, the accompanying dataset, has 1,575 multi-view sequences spanning 229 objects, with reconstructed interactions retargeted into robot references.
- Training combines proximal policy optimization with behavioral cloning, recycling verified successful executions into demonstrations.
- Without finetuning, one checkpoint reaches 86.79% success on unseen trajectories of training objects and 57.32% on held-out objects.
- The paper reports beating state-of-the-art bimanual tracking baselines by 77.36 and 45.73 percentage points.
Why it matters
Most dexterous tracking work so far has dealt with one hand and a narrow range of interactions. Many everyday tasks use two hands, and the authors argue that this bimanual behavior has been left unaddressed. DONIC is their attempt at a single policy that covers it, trained across different operation categories and human-motion sources rather than one task at a time.
Who it affects
Mainly researchers working on robot dexterous manipulation and on learning from human demonstrations. BiHOI, with 1,575 sequences over 229 objects, is aimed at the data scarcity the authors name as a core obstacle for bimanual work.
How to use it
This is a research result, not a product. No code, model or dataset release is mentioned. For practitioners, the useful parts are the described recipe: mixing proximal policy optimization with behavioral cloning in a loop that feeds verified successes back as demonstrations, an object-centered per-hand reward, and Clip-Centered Advantages.
How solid is it
The numbers come from the paper's own abstract-level summary on Hugging Face Papers. A single checkpoint without finetuning scores 86.79% on unseen trajectories of training objects and 57.32% on held-out objects. The gains over baselines are given only as percentage-point margins (77.36 and 45.73), with no baseline scores shown. The source does not name the baselines or say what simulator or environment the success rates were measured in.
Risks and caveats
Generalization to new objects is much weaker than to new trajectories of familiar objects: 57.32% against 86.79%. No real-robot hardware experiments are mentioned; the results are described only as success on unseen trajectories and held-out objects. The source does not say which margin belongs to which evaluation split. Claims such as being the first generalist bimanual tracker are the authors' own.
“Together, these designs enable one single policy to learn coordinated manipulation across heterogeneous references.”
— DONIC paper abstract, Hugging Face Papers