Shanghai AI Laboratory unveils InternW0, a physical world model for robots
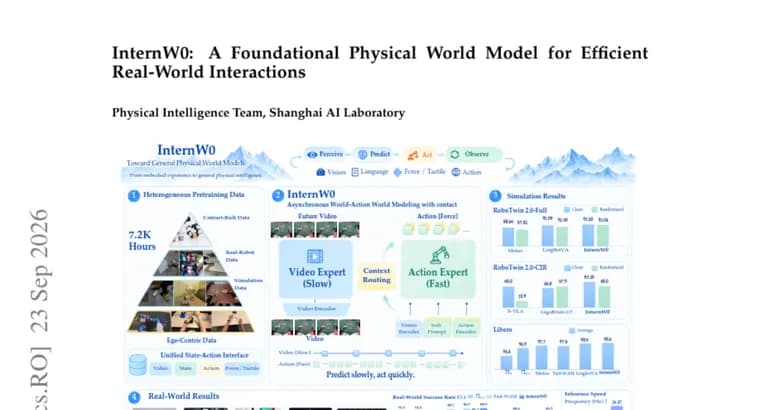
Shanghai AI Laboratory has introduced InternW0, described as the first instantiation of its InternW physical world model series. The model is built to do two things at once: predict future visual dynamics of a scene and generate continuous robot control, using what the authors call an asymmetric video-action architecture with flow matching. A high-capacity 'video expert' component handles longer-horizon predictions of how the world will look, while a separate, lightweight 'action expert' operates on a faster timescale to control the robot. Rather than recomputing its predicted future from scratch every time it issues a new action, InternW0 reuses layerwise key/value information from earlier computation and adapts it to newly observed states, a mechanism the authors call observation-conditioned context routing. The system also includes domain-specific interfaces and soft prompts meant to let it work across different robot embodiments, plus contact-aware post-training that incorporates force and tactile signals for tasks involving physical contact and manipulation. InternW0 was trained on approximately 7,200 hours of heterogeneous robot and egocentric (first-person) data, including EgoLab, a 275-hour egocentric dataset collected in a real laboratory setting. The authors evaluated the model on simulation benchmarks as well as real-world scientific tasks: a 15-stage metal-organic framework synthesis workflow, and a 5-stage contact- and force-aware dexterous manipulation task for general-purpose quantitative pipetting. The source material does not include named individual authors, a publication date, or any benchmark scores or comparisons against other models.
Key facts
- InternW0 is the first instantiation of Shanghai AI Laboratory's InternW physical world model series.
- It jointly predicts future visual dynamics and generates continuous robot control via an asymmetric video-action architecture using flow matching, with a high-capacity video expert and a lightweight, faster action expert.
- It reuses layerwise K/V information via observation-conditioned context routing instead of regenerating predicted futures for every action update.
- Training used about 7,200 hours of heterogeneous robot and egocentric data, including EgoLab, a 275-hour real-laboratory egocentric dataset.
- Real-world evaluation included a 15-stage metal-organic framework synthesis workflow and a 5-stage contact- and force-aware dexterous manipulation task for quantitative pipetting.
Why it matters
Most world models are built to predict how a scene will evolve, but that prediction becomes stale the moment the world changes in response to an action. InternW0's pitch is to keep prediction and control tightly coupled, so the model's sense of 'what happens next' updates as the robot actually acts, rather than being recomputed from scratch or drifting out of sync. Shanghai AI Laboratory frames this as a step toward physical world models that are scalable, asynchronous and usable for real scientific work, not just simulated benchmarks.
Who it affects
The work targets robotics and embodied-AI researchers building systems that need to plan and act in physical environments, and specifically the emerging niche of lab-automation robotics: the two real-world evaluation tasks described, a multi-stage metal-organic framework synthesis workflow and force-aware pipetting, point at automating scientific experimentation rather than warehouse or household robotics.
How to use it
InternW0 is presented as a research model rather than a released product. It was evaluated on simulation benchmarks alongside two real-world tasks: a 15-stage metal-organic framework synthesis workflow and a 5-stage contact- and force-aware dexterous manipulation task for general-purpose quantitative pipetting. The source does not state a release date, licensing terms or availability for outside use.
How solid is it
The available material is a short paper abstract without named individual authors, a publication date, or quantitative benchmark scores or comparisons to other models. The architectural claims, such as the asymmetric video-action design and observation-conditioned context routing, come directly from the authors' own description rather than from independently reported results.
Risks and caveats
Without benchmark numbers or head-to-head comparisons in the available text, it is not possible to gauge how InternW0 performs relative to other physical world models or robot-control systems. The pre-score note that flags this as a solid but incremental contribution in an active research field is consistent with what the abstract itself supports: a new architecture and evaluation setup, without evidence yet of a decisive performance leap.